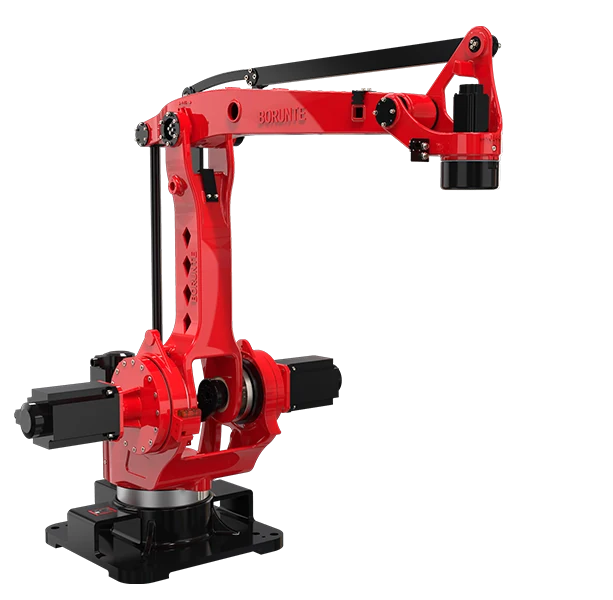
A robot may load and unload a CNC machine, lathe, press or other equipment, but part orientation and reliable gripping determine the handling method.
ROBOT APPLICATIONS
CNC Machine Tending with Robots
Plan the process before selecting a model.
01APPLICATION OVERVIEW
Design around the complete process.
A machine-tending cell coordinates raw-part presentation, gripping, machine-door and chuck or fixture actions, cycle signals, finished-part placement and operator access. The interface with each machine should be checked before a robot is specified.
Machine signals, door control, cycle start and fault recovery need an agreed interface. The existing machine controller and available I/O influence the integration approach.
A practical layout leaves space for raw and finished parts, tool changes, maintenance and safe intervention. Evaluate the complete cycle, including the machine process and transfer time.
02PROJECT BRIEF
What to share with the team.
These inputs help narrow the cell concept and suitable robot range. Final suitability, safety measures and dimensions must be confirmed for the actual site and equipment.
- Machine make, model, controller and available interface documentation
- Part dimensions, mass, orientation, batches and incoming/outgoing presentation
- Current cycle time, target output, shift pattern and available cell footprint
PROJECT ENQUIRY
Let’s engineer the
right solution.
Tell us what your process needs to do.